inquiry
Leave A Message
If you are interested in our products and want to know more details,please leave a message here,we will reply you as soon as we can.
submit
Home

Blog

Blog

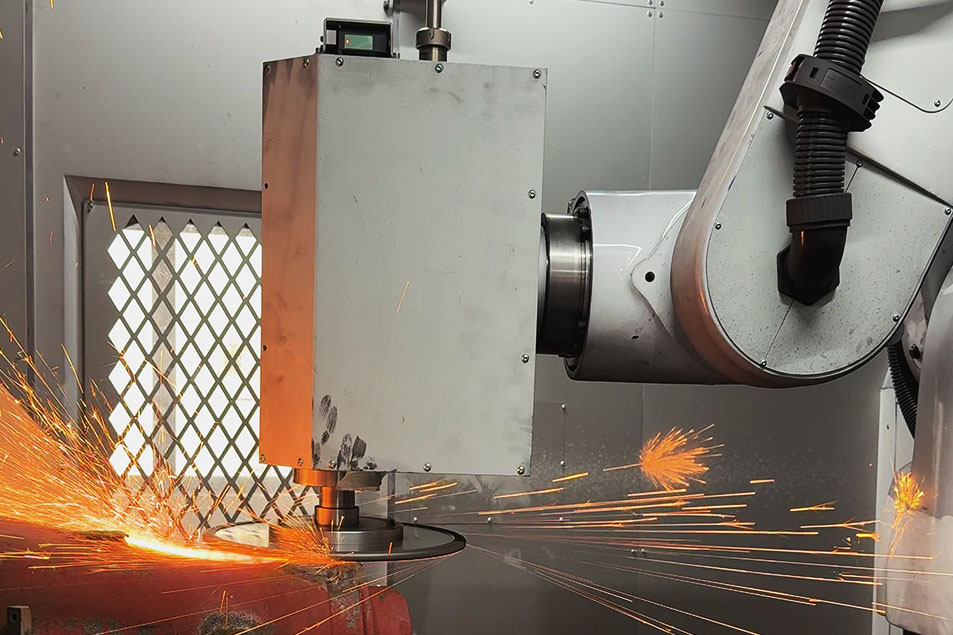
  • Foundries Can’t Keep Grinders. What Work Can a Grinding Robot Actually Take?
    Foundries Can’t Keep Grinders. What Work Can a Grinding Robot Actually Take?
    Sep 10, 2026
    Foundries Can’t Keep Grinders. What Work Can a Grinding Robot Actually Take?     The hardest shift to staff in a foundry is often not melting or molding. It is grinding. Day shift can still be patched together. Night shift, hot weather, and year-end rush orders are when the finishing room empties first. The work is not optional. Unground gates, proud parting lines, and hole-edge burrs show up later in machining, assembly, and paint. The job is dirty, loud, and dusty. Numb hands and sore wrists are normal. When a skilled grinder leaves, you do not replace the “feel” in a week. Most plants looking at grinding robots are not chasing a slogan. They are asking a simpler question: can this line still ship tomorrow. What actually wears people out From outside, grinding looks like an angle grinder on a casting. Anyone who has stood in the booth knows fatigue is only part of it. The harder problem is inconsistency. Castings from the same mold and the same heat do not arrive the same. Gate stubs vary in height. Flash is thick on one piece and thin on the next. Some parts are slightly warped. Some cavities will not accept a wheel. A skilled operator compensates by pressure, angle, and a couple of extra passes. A new hire under-grinds or knocks a datum face down. Piecework continues. Quality starts to drift. Turnover makes it worse. Training a finisher takes time. Losing one experienced person takes cycle time and rework with them. Job ads can stay online. Castings will not wait. Dust and labor rules are also pushing the job out of the plant. Iron dust, aluminum smear and noise, steel cutting load—none of that is solved by handing out earplugs. “Just hire two more people” is getting harder to use as a finishing strategy. That is why automated grinding is entering foundries. Finishing has started to hold the whole line back. Why casting grind is more awkward than machining Machining starts from a blank that already has datums and tighter stock. Casting grind starts from something else. Gate remnants can be high. Cutting force jumps immediately. Parting lines, vents, cold-shut edges, and ingates are irregular. The tool has to reach in without thinning the wall next to it. Sand castings and permanent-mold parts, iron and die-cast aluminum, do not leave the same burr. Die-cast flash can be thin and long. A sand-cast gate can be thick and hard. Then there is casting variation. A millimeter or two on the same part number is not rare. A robot that only repeats one frozen path will grind air one day and cut into a rib the next. That is why a demo video can look clean and the same cell can disappoint on a real floor. Demo parts are usually better behaved than incoming work. The hard part is not whether the arm can move. It is whether three things can hold at once: the part can be located with acceptable repeatability; the path can move with the casting error; tooling and force can change by material and by feature. Miss one, and the cell still runs. The quality does not. What a robot can take—and what it should not Start with the good fit. Stable volume, a short list of part numbers, and a grinding spec you can write down. Housings, brackets, valve bodies, wheel-type parts where the same gates, the same flash lines, and the same hole edges come back every day. That repetition is what a cell is built for. Dual stations exist for a practical reason: grind on one side, load on the other, so the machine is not waiting. For mid-volume small and medium iron or aluminum parts, that layout matches finishing better than a single fixture and a standing robot. Heavy gates and thick flash are where people fade. Handheld tools lose force late in a shift and the cut goes uneven. A rigid, high-payload grinding unit is often steadier there. What matters on site is whether the table and arm can take the cutting force, and whether the enclosure actually contains dust and sparks—not how the machine photographs. Now the poor first candidates. Job shops with constant part-number changes will burn time on fixtures and teaching. If the casting may be revised before the clamp is finished, the cell becomes furniture. That is not “automation is impossible.” It means changeover rate and who owns the program have to be answered first. Parts with almost no stable datum, or with very large piece-to-piece spread, also need caution. A dead path without measurement and compensation can create more rework than a person. Distortion-prone parts—thin aluminum walls, some covers—need force control, not more stiffness. If the machine cannot go light where it must go light, cosmetic faces ripple. One more miss: grinding is only one slice of finishing. If cutting and shot blast are unstable, and sorting and transfer are still a crowd of people, one grinding booth just moves the bottleneck a meter downstream. Iron, aluminum, steel, and mega die cast are not the same job Cast iron: hard gates, heavy dust, fast wheel wear. The unit has to hold load, and dust collection cannot be decorative. Once iron volume is there, dual stations and dual spindles show up because waiting time is expensive. Aluminum is different. It smears. Surfaces mark easily. Many aluminum jobs need flash gone and edges even, without wounding a datum. Tools change: disc cutters, mills, belts, brushes. An iron-grinding wheel strategy does not transfer. Thin walls need fine current, position, and torque loops. If those loops are crude, appearance parts show waves. Steel asks for rigidity. The same gate size cuts harder than iron. If payload and table capacity are short, a pretty path still chatters. Large integrated die-castings are another project type. Big envelopes, long flash, many surfaces, and a takt set by the die-cast cell. Scaling a standard booth is not the work. Floor space, handoff from the casting island, and fixture strategy decide the project. You do not buy “a robot.” You buy a finishing method for a material, a geometry, a volume, and a process. What plants usually underestimate Fixtures. Simple nests are fast and cheap, and they move. Self-clamping nests are stable and slow to build. Some machines add a press-down axis to drop some cylinder modules and cover more part numbers. “The robot has a camera, just dump the parts” is still rare on real foundry floors. Vision and auto-locate, when they are used, are there to cut hard locators and cut reteaching—not to delete fixturing. Consumables and process. Wheels, burrs, discs, flap wheels, rotary files for iron and steel; a different set for aluminum. The wrong tool on the right machine still makes scrap. A cell does not arrive knowing which cutter belongs on which feature. Incoming consistency. Mold upkeep, pouring stability, and how the gate was cut before grind all land on the program. Compensation can swallow some size scatter. It cannot swallow a process that is not under control. Before automation, tighten gate location and flash condition. Do not ask the cell to eat every upstream swing. Ownership. Someone has to own programs, changeovers, wheel changes, and compensation values. A supplier cannot live in the plant forever. If nobody on the floor will touch the teach pendant, a good start-up decays in a few months. Four questions before you buy Will these part numbers still run in six months? Is there enough daily volume to feed a full shift? Can process engineering mark the gates, the flash, and the faces that must not be touched? Is there a person who will own fixtures and programs? If two of those are blank, do not start with “lights-out.” Start with the dirtiest, heaviest, most repetitive features. Lock takt and quality. Then decide whether bin picking, infeed conveyors, or sorting belong in the next step. For foundries and die-casters that already have stable volume, the value is usually plain: quality that does not collapse when a skilled grinder quits; finishing that can still run on night shift; fewer dust and labor fights; the same part number finished to the same standard, regardless of who is on the wheel that day. Companies that live in casting finishing—Neview is one of them—are judged on whether compensation tracks casting scatter, whether a heavy gate can be cut, whether aluminum can be worked lightly, whether iron and steel can be held, and whether the grind cell can connect to handling later. Those points only mean something against a real part and a real volume. Automated grinding will not clean up an entire foundry. It is good at the work that repeats every day, can be specified, and has already worn people down. The shop-floor test is still the same: when the skilled hand is gone, does the part still come out the same.  
    Read More
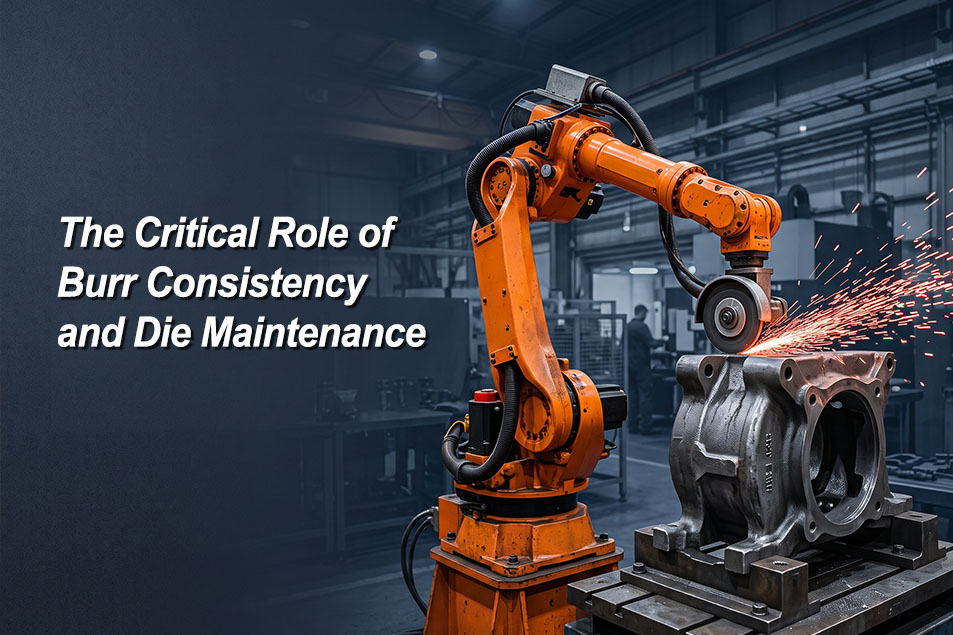
  • Failure Analysis and Countermeasures for Automated Deburring of Die Castings
    Failure Analysis and Countermeasures for Automated Deburring of Die Castings
    Sep 03, 2026
    Failure Analysis and Countermeasures for Automated Deburring of Die Castings AbstractAutomated deburring of die castings is theoretically considered easier to implement than for iron or steel castings because die castings have better surface quality and burrs are concentrated at relatively fixed locations such as parting lines, gates, vents, and ejector pin marks. However, actual operating data from multiple die casting shops show that robot deburring cells commonly experience missed spots, over-grinding, tool collisions, and yield degradation after only three to six months of production, with some equipment eventually idled or reverted to manual operation. This article analyzes the process characteristics of die casting production and identifies three core factors causing automation failure: burr size variation due to die wear, lack of reliable positioning datums on raw parts, and insufficient deburring tool management. The study argues that the prerequisite for successful die casting deburring automation is not higher robot accuracy or faster force control response, but rather the establishment of a preventive die maintenance system, reliable workpiece positioning solutions, and closed-loop tool life management. The article concludes with improvement paths and implementation recommendations for different die casting production scenarios. Keywordsdie casting deburring automation; burr consistency; die wear; positioning datum; tool management 1 IntroductionDie casting produces parts with relatively high dimensional accuracy, good surface finish, and fast cycle times, widely used in automotive, telecommunications, power tools, and home appliance industries. After ejection, die castings typically require removal of gates, vents, flash, and ejector pin protrusions, collectively referred to as burrs. Manual deburring has long relied on pneumatic files, rotary burrs, and sandpaper, with high labor intensity, obvious dust and noise hazards, and poor consistency. Therefore, the die casting industry has a strong practical demand for deburring automation. From a technical perspective, burr positions on die castings are relatively fixed, theoretically making them suitable for automated removal by robots with floating tools. However, in actual projects, many die casting plants have invested hundreds of thousands or even millions of RMB in robot deburring cells, only to encounter various problems after a few months of operation: some products show rising missed-spot rates requiring full manual inspection and repair; some suffer over-grinding leading to scrap; some experience frequent tool collisions causing spindle damage. These problems erode management confidence in automation, and equipment gradually sits idle. This article analyzes the deep causes of die casting deburring automation failure based on investigations and project reviews in multiple die casting shops. The analysis is not limited to the robot itself but covers die casting molds, raw part condition, positioning methods, tool consumption, and on-site management, aiming to provide actionable improvement directions for die casting plants. 2 Burr Size Variation: The Direct Consequence of Die WearBurrs on die castings primarily form at the parting surface. Die casting molds are subjected to alternating clamping force and thermal stress from high-speed, high-pressure molten metal injection, causing wear, edge collapse, and localized depression on the parting surface. New molds or freshly repaired molds have tightly closed parting surfaces, with flash thickness typically between 0.1 mm and 0.3 mm—thin and uniform, allowing robots to remove it stably with fixed trajectories and minimal floating compensation. But as mold usage accumulates, the parting surface gap gradually increases, and flash thickness can grow from 0.3 mm to over 1 mm, sometimes exceeding 2 mm in severe local areas. This variation in burr thickness is devastating to robot deburring. Under fixed trajectory mode, the robot follows preset paths and pressure. When burrs suddenly thicken, if the force control system does not respond quickly enough, the tool will either over-cut the workpiece body or under-cut the burr. Even with force-controlled spindles, response time is typically in the tens of milliseconds, offering limited adaptability to sudden burr changes. Moreover, if force control parameters are set too sensitively, vibration occurs even in normal burr areas, affecting surface quality. The fundamental solution is die maintenance. Die casting plants should establish a preventive die maintenance system, incorporating parting surface flatness inspection into daily checks. Specific practices include: inspecting parting surface wear every certain number of shots (e.g., 5,000 to 10,000 shots, depending on product size and alloy type), measuring parting surface gap with feeler gauges, repairing collapsed edges by welding and grinding, and promptly replacing worn inserts and ejector pins. The goal is to control burr thickness within a preset range, such as no more than 0.5 mm. Only when burr size is stable can robot trajectories and force control parameters remain effective over the long term. 3 Lack of Positioning Datum: Strict Requirements on Raw PartsRobot deburring demands far higher workpiece positioning accuracy than manual work. Manual operators can watch the workpiece and adjust file angles accordingly, while robots rely on preset coordinate systems. If the workpiece is not placed in a consistent position each time, the robot grinding trajectory will deviate from the actual burr location. Die cast raw parts usually enter deburring directly without machining, lacking precision datum surfaces. Fixtures often locate on raw surfaces, ejector pin bosses, gate stubs, or sidewall profiles. These features have draft angles, ejection deformation, and position deviations. For example, ejector pin boss height may vary due to ejector mechanism wear, gate stub length differs due to injection parameter fluctuations, and raw surfaces warp from uneven shrinkage. These accumulated deviations can cause the actual workpiece position on the fixture to differ from the theoretical position by 0.5 mm to 2 mm. For deburring processes requiring accuracy within 0.3 mm, such positioning error is unacceptable. There are several ways to solve the positioning problem. First, control the tolerances of key locating features at the die casting stage, such as designing dedicated locating bosses on the mold and stabilizing their dimensions through injection parameters. Second, add a simple machining operation before deburring to mill a flat datum or drill a locating hole, providing a stable reference for the robot. Third, use vision guidance for rough position compensation, where cameras recognize workpiece contours or feature points, calculate offsets, and correct robot trajectories. Vision solutions face interference from oil, reflections, and surface oxidation color differences in die casting shops, and their recognition stability still needs improvement, making them more suitable as auxiliary means rather than the sole dependency. 4 Lack of Tool Management: An Open-Loop System Causes Yield DecayDie castings are primarily aluminum and zinc alloys with relatively low hardness, but rotary burrs, grinding discs, and flap wheels still wear. Aluminum has a special problem: aluminum chips tend to adhere to tool surfaces, forming built-up edges that reduce cutting efficiency and scratch workpiece surfaces. If tool condition is not managed, robot deburring quality gradually declines with running time, dropping from initial pass rates above 95% to 80% or lower. Most die casting plants pay insufficient attention to tool management. In manual deburring, workers judge tool sharpness by feel and replace dull tools casually without cost awareness. But once a robot deburring cell is established, tool replacement must be institutionalized. Without tool life records and condition monitoring, the robot becomes an open-loop system: inputs are raw parts and tools, output is the deburred workpiece, but there is no feedback in between, and quality decay cannot be detected in time. Improvement measures include: establishing a tool life statistics table recording the number of parts ground and replacement time for each tool; monitoring spindle current trends and prompting tool replacement when current drops significantly or fluctuates abnormally; for high-volume products, configuring automatic tool changers or multi-station tool magazines to reduce manual intervention. Tool costs should be included in the operating cost accounting of the automation system, and die casting plants must not ignore this item when calculating return on investment. 5 Application Scenario Analysis and Implementation RecommendationsDie casting deburring automation is not suitable for every product. Conditions favoring automation include: single product with high volume, annual output exceeding 50,000 pieces; a sound die maintenance system with controlled burr thickness variation; burr positions concentrated in robot-reachable areas; and product geometry allowing reliable positioning; product design tolerating certain deburring variation. For multi-variety small-batch production or severely worn dies, blindly adopting robot deburring carries high risk. It is better to start with local automation on the most regular and concentrated burr locations, such as gate sawing or parting line grinding, while keeping other areas manual and transitioning gradually. Before investment, conduct a burr consistency test: collect burr height data from at least three batches with thirty pieces per batch, calculate mean and standard deviation, and use the results to set trajectory compensation amounts and force control parameters. 6 ConclusionThe main reason die casting deburring automation fails is not immature robot technology but insufficient process stability. The solution path must address die maintenance, raw part positioning, and tool management to establish a closed-loop control system. Only when burr size variation is controlled, positioning is reliable, and tool condition is manageable can robot deburring achieve long-term stable operation. Die casting plants should include die maintenance costs and tool management costs in total investment evaluation when making automation decisions, avoiding the mistake of only calculating equipment purchase price while ignoring operating costs.
    Read More
  • Key Issues in Selecting Grinding Robots for Castings — A Practical Shop-Floor Perspective
    Key Issues in Selecting Grinding Robots for Castings — A Practical Shop-Floor Perspective
    Sep 03, 2026
    Key Issues in Selecting Grinding Robots for Castings — A Practical Shop-Floor Perspective AbstractImproper selection of grinding robots for castings is a common problem in foundry automation projects. This article systematically examines three critical factors from an engineering application standpoint: workpiece positioning and raw casting dimensional consistency, abrasive wear compensation, and the match between programming/maintenance capability and production volume. The analysis shows that robot arm specifications are not the primary selection criterion. Instead, peripheral process design and production characteristics determine project success. The article concludes with selection recommendations for different production scenarios. Keywordscasting grinding robot selection; workpiece positioning; abrasive wear compensation; production batch size; automated grinding 1、IntroductionFoundries typically adopt grinding robots due to labor shortages, rising manual grinding costs, and harsh working conditions. However, field observations show that a significant portion of installed grinding robots operate at low utilization or sit idle. Most failures are not caused by insufficient robot performance, but by inadequate evaluation of process conditions, product characteristics, and in-house maintenance capability during the selection stage. This article discusses the often-overlooked aspects of grinding robot selection based on real foundry situations. 2、Workpiece Positioning: An Underestimated Prerequisite for AutomationManual grinding allows workers to adjust part position and orientation flexibly to accommodate raw casting deformation and dimensional variation. Robot grinding requires the workpiece to enter the working zone in a repeatable position every time. If positioning error exceeds the grinding trajectory tolerance, the result is missed spots, over-grinding, or tool collision. In production, sand casting raw dimensions often fluctuate by ±2 mm or more, and thin-wall parts warp further after heat treatment. If the fixture design is poor — for example, using two rigid pins when the cored holes are offset — loading becomes difficult, or forced loading shifts the part out of position. Therefore, before selection, foundries must statistically evaluate raw casting dimensional consistency. If necessary, add a rough machining operation to create a stable datum, or adopt flexible positioning solutions. 3、Abrasive Wear Compensation: The Core Dynamic Process ChallengeGrinding discs, rotary burrs, and flap wheels used in casting cleanup are high-consumption tools with much faster wear rates than metal cutting tools. Under fixed-path programming, tool diameter reduction changes the contact position and grinding pressure, causing deburring quality to degrade over time. Some systems use floating spindles or force control for passive compensation, but these only mitigate uniform wear and respond poorly to sudden burr thickness changes. A more reliable approach is to establish abrasive life management, including scheduled replacement intervals, spindle current monitoring, or vision-based remaining tool size detection. When selecting a system, pay close attention to whether the controller supports parameterized wear compensation and tool life statistics. 4、Programming and Maintenance Capability: The Overlooked Long-Term CostGrinding robot trajectory programming is more complex than welding or material handling. Curved surfaces, hole openings, and corners require frequent orientation adjustments and collision avoidance, leading to long commissioning times — from several days to several weeks per product. After startup, product tweaks, abrasive changes, and batch variations all require program parameter modifications. If the foundry has no dedicated person responsible, and relies entirely on the integrator's remote support, downtime increases significantly. Maintainability should be a key selection criterion, including programming interface usability, parameter backup and recovery functions, and training duration. At the same time, the plant should train at least one technician who can handle basic alarms and program adjustments. 5、Production Volume and Part Complexity: The Boundary of Automation EconomicsA common misconception is that more complex castings automatically justify higher-configuration robots. In reality, automation economics depend first on production volume, then on geometric complexity. For annual volumes below a few thousand pieces, programming and commissioning costs amortize poorly, and frequent changeovers reduce equipment utilization. Conversely, products with annual volumes above tens of thousands, stable dimensions, and fixed burr locations offer strong automation value even if moderately complex. Before selection, conduct a product-process match analysis: count grinding points, evaluate reachability, measure dimensional variation range, and record monthly output. Then decide on robot type (standard six-axis, collaborative, or dedicated grinding cell) and peripheral configuration level.   6、ConclusionThe core of casting grinding robot selection is not comparing arm payload and repeatability. The real issues are workpiece positioning reliability, abrasive wear compensation strategy, in-house programming/maintenance capability, and the match between product volume and complexity. Foundries should complete raw casting statistical analysis, grinding point reachability mapping, and payback period calculation before procurement to avoid idle equipment caused by inadequate peripheral support.
    Read More
  • Eliminating Downtime: How Offline Programming (OLP) and Digital Twins Enable Seamless Job Changeovers in Robotic Grinding
    Eliminating Downtime: How Offline Programming (OLP) and Digital Twins Enable Seamless Job Changeovers in Robotic Grinding
    Aug 18, 2026
    Eliminating Downtime: How Offline Programming (OLP) and Digital Twins Enable Seamless Job Changeovers in Robotic Grinding For many small-to-medium foundries operating under high-mix, low-volume (HMLV) production models, the primary hesitation when considering grinding automation is: "With our diverse product portfolio, if every job changeover requires hours or days of line downtime for re-programming, overall productivity will actually drop." Traditional hand-teaching or online programming indeed consumes precious cell runtime. However, the integration of Offline Programming (OLP) and Digital Twin technologies has completely resolved this operational bottleneck: Zero-Downtime Virtual Programming: Engineers import the 3D CAD models of castings directly into the OLP environment. Within a virtual simulation, the software automatically detects parting lines, flash, and burrs, generating optimized toolpaths and spindle orientations. The entire programming cycle takes place 100% in the background without stopping the active robot cell. Collision Detection and Cutting Simulation: The digital twin predicts cutting dynamics, joint limit reachability, and potential fixture interferences prior to execution, ensuring that uploaded programs are 100% safe and execution-ready. Near-Instant Job Changeover: When transitioning production to a new casting part number, operators simply load the pre-configured offline program via the HMI touchscreen. The grinding robot resumes operation within seconds. Powered by NEVIEW's intelligent software suite, foundries with highly variable product lines can now fully unlock the speed, repeatability, and flexibility of modern robotic finishing.
    Read More
  • Building a Green, ESG-Compliant Foundry: Full Enclosures and Dust Control in Modern Robotic Grinding
    Building a Green, ESG-Compliant Foundry: Full Enclosures and Dust Control in Modern Robotic Grinding
    Aug 17, 2026
     Building a Green, ESG-Compliant Foundry: Full Enclosures and Dust Control in Modern Robotic Grinding  In today's global industrial landscape, ESG (Environmental, Social, and Governance) principles and green manufacturing are no longer distant slogans—they represent mandatory regulatory mandates directly impacting foundries worldwide. For decades, traditional casting grinding shops have been labeled as hazardous, high-pollution facilities due to deafening noise, airborne metallic dust, and elevated workplace injury risks, acting as severe stumbling blocks to green transitions. Implementing NEVIEW Fully Enclosed Robotic Grinding Workstations provides far more than capacity expansion; it is the ultimate pathway for foundries to upgrade into modern, eco-friendly smart facilities:   100% Source Dust Capture for a Zero-Dust Workspace (Environmental Focus): Manual grinding allows dangerous metallic particles to scatter uncontrollably. NEVIEW workstations feature fully enclosed heavy-duty acoustic enclosures operating under continuous negative pressure. Integrated with spark arrestors and explosion-proof dust collectors, the system captures and filters 100% of metallic dust right at the source, eliminating dust explosion hazards and dramatically improving air quality.   Drastic Shop-Floor Noise Suppression: Heavy acoustic enclosure walls suppress deafening grinding noise exceeding 100 dB down to below 80 dB, bringing the facility in full compliance with global occupational health standards.   Protecting Human Health and Safety (Social Focus): The true value of automation lies in its respect for worker well-being. When grinding robots take over hazardous deburring tasks, human operators move to safe, climate-controlled rooms to oversee system operations. This completely eradicates severe risks like pneumoconiosis, Vibration White Finger (VWF), and projectile injuries. Embracing green grinding automation empowers foundries to navigate strict environmental codes effortlessly while solidifying a responsible corporate image globally—securing long-term orders from blue-chip international buyers who prioritize ESG compliance.
    Read More
  • Manual Teaching vs. Smart Force Control: How Foundries Choose the Right Robotic Grinding Solution
    Manual Teaching vs. Smart Force Control: How Foundries Choose the Right Robotic Grinding Solution
    Aug 14, 2026
    Manual Teaching vs. Smart Force Control: How Foundries Choose the Right Robotic Grinding Solution Investing in a grinding robot system represents a major capital expenditure decision for any foundry embarking on its modernization journey. However, with diverse automation options on the market, many facilities fall into the trap of purchasing equipment they cannot operate effectively. When evaluating robotic solutions, foundries must choose the right system based on part complexity, shop environment, and technical capacity: 1. Manual Teaching Grinding Robots (Foolproof Operation, Rugged & Cost-Effective) For many small-to-medium foundries or facilities lacking dedicated, high-cost robotics programmers, NEVIEW Manual Teaching Grinding Robots offer an ideal, practical solution:   Zero Programming Barrier: Operators do not need to write complex code. A 50-year-old shop technician can hand-guide the robot once using a teach handle; the robot then perfectly replicates the skilled worker's motions in just 5 minutes 。   Superior Dust Resistance & Durability: By omitting delicate 3D optical cameras that often clog or fault in heavy metallic dust environments, these systems deliver high mechanical rigidity and virtually zero maintenance overhead.   Rapid Return on Investment: Without expensive software licensing fees, the initial CapEx is minimized, enabling foundries to recoup their investment in as little as 8 to 12 months. 2. Active Force Control & 3D Vision Systems (For Complex Parts & Premium Quality) For high-volume, highly complex castings with inconsistent burrs (such as engine blocks, wind turbine hubs, or hydraulic valves):   Adaptive 3D Vision: Conducts millisecond-level point-cloud scans prior to grinding, dynamically compensating for casting dimensional variations without expensive precision fixtures.   Active Force Control: Integrated end-of-arm torque sensors (constant-force floating heads) "feel" surface contours in real-time, dynamically adjusting pressure within microseconds to eliminate over-cutting and surface gouges. Essential System Architecture Factors   Process Setup: Select either Part-to-Tool (robot holds small-to-medium castings against fixed belt grinders) or Tool-to-Part (robot manipulates heavy grinders to process fixed multi-ton castings) based on part weight.   Protection Rating: Ensure the industrial robot body and end-of-arm spindles carry at least an IP67 protection rating to guarantee long-term reliability amidst abrasive metal dust.
    Read More
  • Overcoming Foundry Labor Shortages: How Grinding Robots are Transforming the Traditional Finishing Shop
    Overcoming Foundry Labor Shortages: How Grinding Robots are Transforming the Traditional Finishing Shop
    Aug 13, 2026
     Overcoming Foundry Labor Shortages: How Grinding Robots are Transforming the Traditional Finishing Shop  In the modern foundry supply chain, the cleaning and finishing shop has long been considered the ultimate bottleneck restricting overall production capacity and delivery lead times. Traditional casting deburring, cleaning, and parting-line grinding rely heavily on intensive manual labor 。 However, this conventional operational model is facing an unprecedented crisis of survival:   Severe Labor Shortages and Workforce Aging: The harsh shop-floor conditions—characterized by toxic dust, deafening noise, and high vibrations—drive younger workers away, leading to severe recruitment difficulties and high turnover.   Escalating Payroll and Compliance Expenses: To retain skilled grinding technicians, foundries must offer premium wages, high-risk allowances, and expensive insurance coverages, severely eroding profit margins.   Poor Product Consistency and High Scrap Rates: Manual grinding is highly vulnerable to physical fatigue and emotional variance. The pressure applied during the first hour differs drastically from that in the eighth hour, frequently causing over-grinding (damaging the base material) or under-grinding (leaving burrs behind). With the rapid adoption of Industry 4.0 and smart manufacturing, implementing grinding robots has become the primary strategic weapon for forward-thinking foundries to break this deadlock. NEVIEW robotic grinding solutions provide three decisive strategic advantages:   Unmatched Surface Consistency: Grinding robots operate strictly according to digital paths and optimized cutting parameters, ensuring identical deburring quality across 100% of castings.   24/7 Continuous Productivity: Industrial robots do not suffer from physical fatigue or shift-change lag, enabling round-the-clock operation to compress delivery lead times significantly.   Enhanced Safety and Elimination of Occupational Hazards: Automation transitions workers from hazardous grinding booths to safe monitoring roles, effectively eliminating long-term risks like pneumoconiosis and Vibration White Finger (VWF). For foundries aiming to sustain long-term competitiveness in today's demanding global market, integrating casting grinding robots is no longer an optional upgrade—it is a critical imperative for corporate survival and growth.
    Read More
  • Calculating the True ROI: How Grinding Robots Pay for Themselves in 12–18 Months for Foundries
    Calculating the True ROI: How Grinding Robots Pay for Themselves in 12–18 Months for Foundries
    Aug 10, 2026
    Calculating the True ROI: How Grinding Robots Pay for Themselves in 12–18 Months for Foundries   For many foundry executives and financial officers, adopting a robotic grinding system is undoubtedly the right direction for facility modernization. However, when evaluating the initial Capital Expenditure (CapEx), the ultimate question remains: "How quickly will this equipment deliver a full Return on Investment (ROI)?" Based on real-world implementation metrics from NEVIEW's global client base, calculating the ROI of robotic grinding should never be limited to simply counting "replaced headcount". Comprehensive economic value spans multiple measurable metrics: Comprehensive ROI = Direct Labor Savings + Scrap Reduction + Consumable Lifespan Extension + Risk Mitigation + Order Premium Substantial Direct Payroll Reductions: Grinding shops demand premium wages and risk allowances. A single industrial grinding robot operates 24/7 across multiple shifts, reliably offsetting the workload of 2 to 3 skilled manual operators while eliminating recruitment overhead. Slashing Scrap Rates by Over 80%: Manual grinding errors frequently cause over-cutting, destroying high-value components. Precise force control cuts casting scrap rates by over 80%, saving tens of thousands of dollars in lost raw materials annually. Consumables Savings Exceeding 30%: By maintaining constant contact pressure and optimal cutting toolpaths, robots eliminate sudden mechanical impacts that destroy abrasive belts and grinding wheels prematurely, extending consumable lifespan by over 30%. Mitigation of Hidden Legal and Health Liabilities: Occupational disease claims (such as pneumoconiosis and Vibration White Finger) represent devastating hidden costs. Transitioning operators away from hazardous grinding booths drastically reduces corporate legal and health liabilities. Scaling Capacity and Winning Premium Global Orders: Flawless, repeatable surface finishes enable foundries to clear stringent quality audits from multinational automotive, aerospace, and energy OEMs, unlocking access to higher-margin contracts. Performance data shows that most foundries fully recoup their capital investment within 12 to 18 months (and as quickly as 8 to 12 months for manual teaching setups), unlocking years of sustained profitability and competitive cost advantages.
    Read More
  • Overcoming Foundry Labor Shortages: How Grinding Robots are Transforming the Traditional Finishing Shop
    Overcoming Foundry Labor Shortages: How Grinding Robots are Transforming the Traditional Finishing Shop
    Aug 08, 2026
      Overcoming Foundry Labor Shortages: How Grinding Robots are Transforming the Traditional Finishing Shop In the modern foundry supply chain, the cleaning and finishing shop has long been considered the ultimate bottleneck restricting overall production capacity and delivery lead times. Traditional casting deburring, cleaning, and parting-line grinding rely heavily on intensive manual labor. However, this conventional operational model is facing an unprecedented crisis of survival: Severe Labor Shortages and Workforce Aging: The harsh shop-floor conditions—characterized by toxic dust, deafening noise, and high vibrations—drive younger workers away, leading to severe recruitment difficulties and high turnover. Escalating Payroll and Compliance Expenses: To retain skilled grinding technicians, foundries must offer premium wages, high-risk allowances, and expensive insurance coverages, severely eroding profit margins. Poor Product Consistency and High Scrap Rates: Manual grinding is highly vulnerable to physical fatigue and emotional variance. The pressure applied during the first hour differs drastically from that in the eighth hour, frequently causing over-grinding (damaging the base material) or under-grinding (leaving burrs behind). With the rapid adoption of Industry 4.0 and smart manufacturing, implementing grinding robots has become the primary strategic weapon for forward-thinking foundries to break this deadlock. NEVIEW robotic grinding solutions provide three decisive strategic advantages: Unmatched Surface Consistency: Grinding robots operate strictly according to digital paths and optimized cutting parameters, ensuring identical deburring quality across 100% of castings. 24/7 Continuous Productivity: Industrial robots do not suffer from physical fatigue or shift-change lag, enabling round-the-clock operation to compress delivery lead times significantly. Enhanced Safety and Elimination of Occupational Hazards: Automation transitions workers from hazardous grinding booths to safe monitoring roles, effectively eliminating long-term risks like pneumoconiosis and Vibration White Finger (VWF). For foundries aiming to sustain long-term competitiveness in today's demanding global market, integrating casting grinding robots is no longer an optional upgrade—it is a critical imperative for corporate survival and growth.
    Read More
  • Beyond Manual Grinding: How NEVIEW Casting Grinding Robots Are Solving the Foundry Labor Crisis
    Beyond Manual Grinding: How NEVIEW Casting Grinding Robots Are Solving the Foundry Labor Crisis
    Aug 08, 2026
    Beyond Manual Grinding: How NEVIEW Casting Grinding Robots Are Solving the Foundry Labor Crisis   Walk into any foundry today, and you’ll likely hear the same pain point: it’s getting harder and harder to find skilled grinding operators. The work is physically demanding, noisy, dusty, and potentially hazardous. Young workers are increasingly unwilling to take on these roles, and the aging workforce means decades of expertise are retiring from the shop floor. For foundries around the world, this isn’t just an HR problem—it’s an existential challenge. NEVIEW provides the answer with advanced casting grinding robots built specifically to handle the harsh realities of post-casting finishing. The True Cost of Manual Grinding Manual grinding appears cheaper at first glance, but hidden costs accumulate fast. Inconsistent pressure leads to over-grinding, scrap parts, and rework. Operators tire, causing cycle-time variations and quality dips during late shifts. There’s also the rising expense of personal protective equipment, ventilation upgrades, and work-related injury claims. When you calculate total cost per acceptable part, manual processes often prove far more expensive than automation. Enter the NEVIEW Casting Grinding Robot NEVIEW casting grinding robots are engineered from the ground up to tackle iron, steel, and aluminum castings of varying complexity. Equipped with high-torque spindles, force-sensing compliance, and intelligent path planning, these robots remove gates, parting lines, and flash with precision that manual operators struggle to match consistently. The enclosed work cell contains dust and noise, transforming a dirty, dangerous corner of the foundry into a clean, monitored, and predictable operation. How Force Control Changes the Game A key differentiator for NEVIEW robotic grinding systems is real-time force feedback. Unlike rigid CNC machines or basic robotic position control, NEVIEW robots feel the part. The end effector maintains a constant contact force against contoured surfaces, automatically compensating for part-to-part dimensional variation—a common reality in sand casting. This adaptive capability means fewer scrapped castings and more uniform output, even as tooling wears or mold shifts occur between batches. Seamless Integration, Not an Island Modern foundries don’t need a standalone robot that creates a bottleneck. NEVIEW designs its grinding cells for easy integration with existing shakeout, shot blasting, and machining lines. The vision system can recognize different part models, call up the correct grinding program, and process mixed batches without operator intervention. This flexibility is essential for jobbing foundries that handle diverse, small-to-medium production runs. Searches like “flexible casting grinding automation” and “NEVIEW foundry robot” naturally bring foundry engineers to content that addresses exactly these challenges. Building Workforce Resilience Far from “stealing jobs,” NEVIEW grinding robots let manufacturers redeploy their best people to higher-value tasks: quality inspection, process optimization, and running multiple cells. Companies that automate grinding report improved employee retention because they can offer upskilling programs rather than condemning workers to a lifetime behind a grinding wheel. This message resonates in recruitment and corporate branding, adding an indirect but powerful SEO and PR benefit. Conclusion The labor shortage in foundries isn’t a temporary trend—it’s a structural shift. Foundries that act now to adopt NEVIEW casting grinding robots will build a competitive moat: consistent quality, controlled costs, and a workforce focused on growth, not just survival. Explore the full range of NEVIEW automated grinding solutions and future-proof your finishing room today.  
    Read More
  • Mastering Heavy-Duty Casting Grinding: How High-Rigidity Industrial Robots Conquer Large Wind Power and Pump Valve Components
    Mastering Heavy-Duty Casting Grinding: How High-Rigidity Industrial Robots Conquer Large Wind Power and Pump Valve Components
    Jul 30, 2026
    Mastering Heavy-Duty Casting Grinding: How High-Rigidity Industrial Robots Conquer Large Wind Power and Pump Valve Components In the heavy machinery, wind power, and petrochemical sectors, the finishing of large-scale castings—such as wind turbine hubs, large pump valve bodies, machine tool beds, and marine propellers—remains one of the most challenging bottlenecks for foundries. These components frequently weigh several tons or tens of tons, featuring thick riser residues, heavy flash, and ultra-hard materials such as alloy steel or ductile iron. Traditional manual grinding forces operators to handle heavy angle grinders or pneumatic chisels for hours on end, posing extreme physical strain and severe safety hazards from flying debris. To address the demanding requirements of heavy-duty casting post-processing, New Horizon has engineered High-Rigidity Robotic Grinding Workstations specifically built for high-payload and high-cutting-force applications. By combining heavy-duty industrial robots with customized high-power spidles, we deliver complete automation for heavy casting deburring and grinding. High-Rigidity Structure & Anti-Vibration Architecture: Powered by industrial robots featuring reinforced gearboxes and heavy-duty bearings, the system withstands intense reaction forces and high-frequency vibrations generated when removing bulky riser stumps, maintaining pinpoint trajectory accuracy. High-Power Motorized Spindles & Constant-Power Cutting: Integrated with high-torque, water-cooled motorized spindles, the system delivers massive cutting torque even at lower RPMs, rapidly removing thick flash and parting lines while boosting productivity by 3 to 5 times over manual methods. Heavy-Duty Repositioning & Complete Safety Isolation: Paired with multi-axis heavy-duty positioners, the robot automatically rotates and reorients massive castings to present optimal cutting angles. Operators monitor the entire process safely outside the enclosed cell, completely eradicating risks from heavy object collisions and projectile debris. Automating the grinding of heavy castings not only eliminates recruitment challenges for high-risk positions but also equips foundries with the formidable manufacturing capability needed to secure high-value global heavy equipment contracts.
    Read More
  • Calculating the ROI: A Comprehensive Guide to Investing in Grinding Robots for Foundries
    Calculating the ROI: A Comprehensive Guide to Investing in Grinding Robots for Foundries
    Jul 30, 2026
    Calculating the ROI: A Comprehensive Guide to Investing in Grinding Robots for Foundries For many foundry executives and plant managers, adopting a robotic grinding system is undoubtedly a clear strategic direction for modern facility upgrades. However, when faced with initial Capital Expenditures (CapEx), the core question remains top-of-mind: "How quickly will this investment deliver a full Return on Investment (ROI)?" In reality, evaluating the ROI of a grinding robot system should never be restricted to the narrow metric of "how many manual workers were replaced." Based on NEVIEW's real-world implementations across global foundry clients, the comprehensive economic value delivered by automated grinding spans multiple impactful dimensions: 1. Substantial Direct Labor Cost Reductions Traditional grinding shops feature harsh environments, forcing facilities to offer premium wages, high-risk allowances, and extensive overtime compensation while enduring high employee turnover. A single grinding robot operates 24/7 across multiple shifts, typically offsetting the workload of 2 to 3 skilled workers while slashing payroll and recruitment overhead. 2. Dramatic Scrap Rate Reduction and Material Savings Manual grinding is highly susceptible to human error, fatigue, and tremors, which lead to over-cutting and dimensional out-of-tolerance rejects. Industrial grinding robots cut scrap rates by over 80% through ultra-precise force control and repeatability. For high-value automotive parts, aerospace castings, or hydraulic valve bodies, scrap reduction alone saves tens of thousands of dollars annually. 3. Mitigation of Hidden Legal and Health Risks Occupational health issues—such as pneumoconiosis, Vibration White Finger (VWF), and workplace injuries—represent severe hidden compliance costs for foundries. Transitioning operators from hazardous grinding booths to safe control rooms eliminates occupational disease claims and lowers corporate health insurance liabilities. 4. Capacity Scaling and Premium Order Margins The continuous, reliable output of industrial robots dramatically compresses delivery lead times. More importantly, impeccable surface consistency allows foundries to effortlessly clear strict quality audits from premium multinational buyers, unlocking access to higher-margin global contracts. According to real-world performance metrics from NEVIEW's client base, most medium-to-large foundries fully recoup their capital investment within 12 to 18 months, unlocking sustained profitability and cost advantages for years to follow.
    Read More
1 2 3 4 5 6 7 8 9
A total of 9 pages

leave a message

leave a message
If you are interested in our products and want to know more details,please leave a message here,we will reply you as soon as we can.
submit
Contact Us: judy@ahxjj.cn

home

products

WhatsApp

Contact Us