Sep 03, 2026
Key Issues in Selecting Grinding Robots for Castings — A Practical Shop-Floor Perspective
AbstractImproper selection of grinding robots for castings is a common problem in foundry automation projects. This article systematically examines three critical factors from an engineering application standpoint: workpiece positioning and raw casting dimensional consistency, abrasive wear compensation, and the match between programming/maintenance capability and production volume. The analysis shows that robot arm specifications are not the primary selection criterion. Instead, peripheral process design and production characteristics determine project success. The article concludes with selection recommendations for different production scenarios.
Keywordscasting grinding robot selection; workpiece positioning; abrasive wear compensation; production batch size; automated grinding
1、IntroductionFoundries typically adopt grinding robots due to labor shortages, rising manual grinding costs, and harsh working conditions. However, field observations show that a significant portion of installed grinding robots operate at low utilization or sit idle. Most failures are not caused by insufficient robot performance, but by inadequate evaluation of process conditions, product characteristics, and in-house maintenance capability during the selection stage. This article discusses the often-overlooked aspects of grinding robot selection based on real foundry situations.
2、Workpiece Positioning: An Underestimated Prerequisite for AutomationManual grinding allows workers to adjust part position and orientation flexibly to accommodate raw casting deformation and dimensional variation. Robot grinding requires the workpiece to enter the working zone in a repeatable position every time. If positioning error exceeds the grinding trajectory tolerance, the result is missed spots, over-grinding, or tool collision. In production, sand casting raw dimensions often fluctuate by ±2 mm or more, and thin-wall parts warp further after heat treatment. If the fixture design is poor — for example, using two rigid pins when the cored holes are offset — loading becomes difficult, or forced loading shifts the part out of position. Therefore, before selection, foundries must statistically evaluate raw casting dimensional consistency. If necessary, add a rough machining operation to create a stable datum, or adopt flexible positioning solutions.
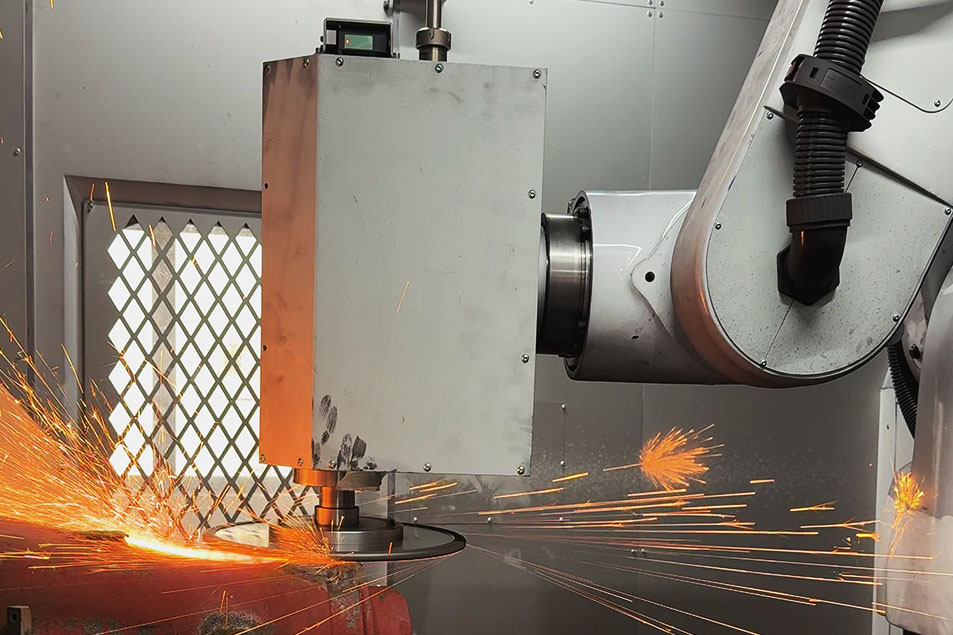
3、Abrasive Wear Compensation: The Core Dynamic Process ChallengeGrinding discs, rotary burrs, and flap wheels used in casting cleanup are high-consumption tools with much faster wear rates than metal cutting tools. Under fixed-path programming, tool diameter reduction changes the contact position and grinding pressure, causing deburring quality to degrade over time. Some systems use floating spindles or force control for passive compensation, but these only mitigate uniform wear and respond poorly to sudden burr thickness changes. A more reliable approach is to establish abrasive life management, including scheduled replacement intervals, spindle current monitoring, or vision-based remaining tool size detection. When selecting a system, pay close attention to whether the controller supports parameterized wear compensation and tool life statistics.
4、Programming and Maintenance Capability: The Overlooked Long-Term CostGrinding robot trajectory programming is more complex than welding or material handling. Curved surfaces, hole openings, and corners require frequent orientation adjustments and collision avoidance, leading to long commissioning times — from several days to several weeks per product. After startup, product tweaks, abrasive changes, and batch variations all require program parameter modifications. If the foundry has no dedicated person responsible, and relies entirely on the integrator's remote support, downtime increases significantly. Maintainability should be a key selection criterion, including programming interface usability, parameter backup and recovery functions, and training duration. At the same time, the plant should train at least one technician who can handle basic alarms and program adjustments.
5、Production Volume and Part Complexity: The Boundary of Automation EconomicsA common misconception is that more complex castings automatically justify higher-configuration robots. In reality, automation economics depend first on production volume, then on geometric complexity. For annual volumes below a few thousand pieces, programming and commissioning costs amortize poorly, and frequent changeovers reduce equipment utilization. Conversely, products with annual volumes above tens of thousands, stable dimensions, and fixed burr locations offer strong automation value even if moderately complex. Before selection, conduct a product-process match analysis: count grinding points, evaluate reachability, measure dimensional variation range, and record monthly output. Then decide on robot type (standard six-axis, collaborative, or dedicated grinding cell) and peripheral configuration level.
6、ConclusionThe core of casting grinding robot selection is not comparing arm payload and repeatability. The real issues are workpiece positioning reliability, abrasive wear compensation strategy, in-house programming/maintenance capability, and the match between product volume and complexity. Foundries should complete raw casting statistical analysis, grinding point reachability mapping, and payback period calculation before procurement to avoid idle equipment caused by inadequate peripheral support.
Read More


 IPv6 network supported